Minseok Kim
Ph.D. Candidate @ VILAB, KAIST

Hello! 👋 I am a 2nd-year Ph.D. student at VILAB, advised by Prof. Kuk-Jin Yoon in the Department of Mechanical Engineering at KAIST.
🔬 Research Interests. My research spans robust 3D perception (LiDAR / Radar) and data-efficient learning (Category Discovery & Dataset Distillation). Recently, my focus has shifted toward understanding human intention in egocentric scenarios — exploring how AI systems can interpret first-person videos to advance next-generation AR / VR and human-robot interaction technologies.
💡 Current Directions.
- Egocentric video understanding (gaze, hand, intention)
- Vision-Language Models (VLM) for scene understanding
- Generalized / Open-world 3D perception
📬 I am always happy to discuss ideas and collaborate on egocentric vision, VLMs, or 3D perception. Feel free to reach out via email!
🎸 Outside of research, I enjoy playing electric guitar, photography, and working out.
News
| May 13, 2026 | Personal webpage is now live! |
|---|
Education
2025.03 – now · Ph.D. candidate, Mechanical Engineering, KAIST
2023.03 – 2025.02 · M.S., Mechanical Engineering, KAIST
2017.03 – 2023.02 · B.S., Mechanical Engineering, Hanyang University
Publications
- PreprintScore Locally, Solve Globally: Training-free Set Decoding for Vision-Language Models2027Preprint
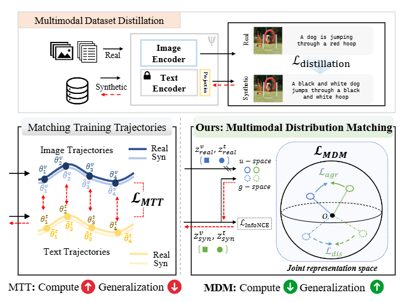
- Preprint
- Preprint
- PreprintZero-Shot Coordination under Partial Observability by Predicting Intention of Partner2026Preprint
- PreprintGaze-hand Trajectory Merging for Efficient Egocentric Video Understanding2026Preprint
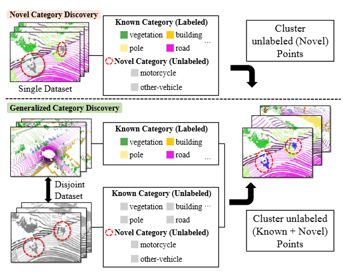
- Generalized Category Discovery for LiDAR Semantic SegmentationIn Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision, 2026
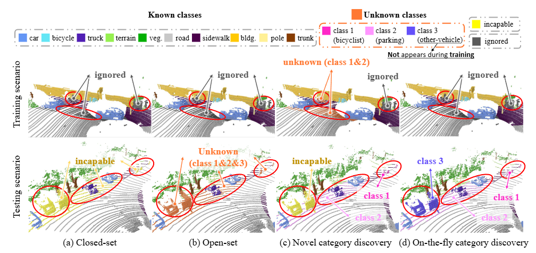
- On-the-fly Category Discovery for LiDAR Semantic SegmentationIn European Conference on Computer Vision, 2024
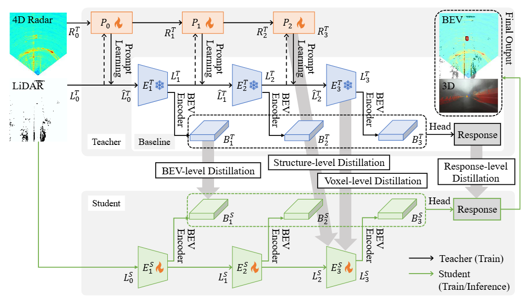
- LiDAR-based All-weather 3D Object Detection via Prompting and Distilling 4D RadarIn European Conference on Computer Vision, 2024
Projects
- Development of Mobility and Connectivity Platform for Unmanned Autonomous Delivery
- Development of quadrupedal robot system technology for surveillance, reconnaissance, and search missions